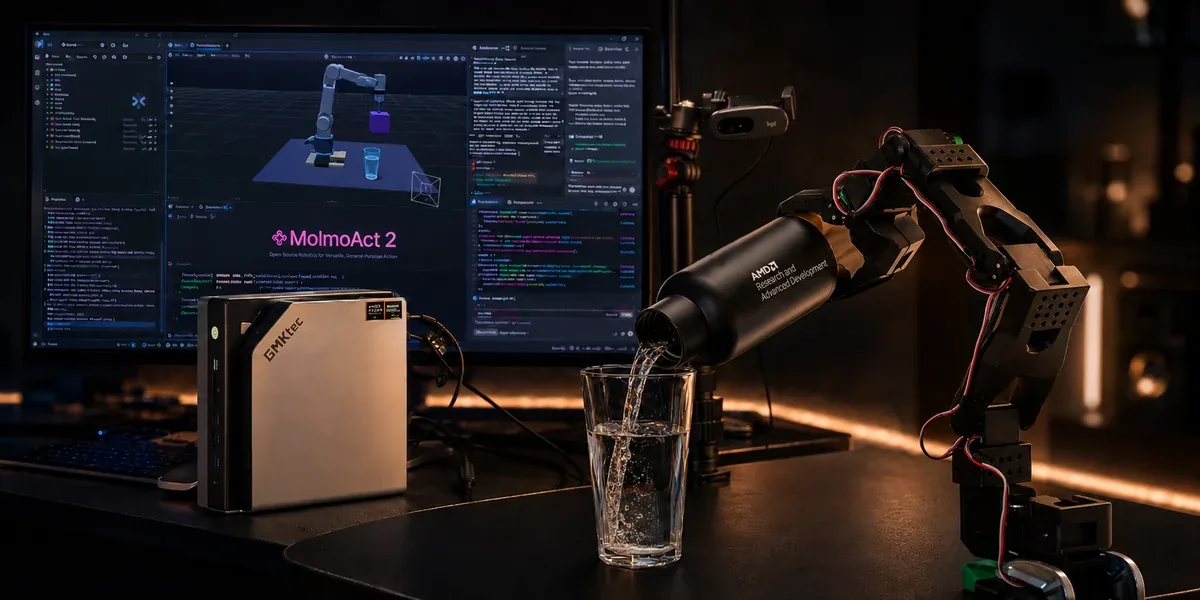
AMD published a tutorial on September 30, 2026 showing how to run the MolmoAct2 vision-language-action (VLA) model on a single Ryzen AI Max+ 395 "Strix Halo" mini PC using the ROCm software stack. The demo drives a robot arm in the LIBERO simulator from a browser, with no cloud or external accelerator. The model, which is open source with weights, training code, and data, pairs a SigLip2 vision encoder with a Qwen3-4B language backbone and a flow-matching action expert that generates short chunks of future motion. The policy outputs end-effector coordinates, deciding where the robot hand should go and whether the gripper opens or closes, which enables cross-embodiment transfer.
The tutorial uses the Ryzers framework, AMD's tool for building and running ROCm Docker containers on Ryzen AI hardware. Setup involves cloning the Ryzers repository, installing the package, and building the MolmoAct2 container. The main interactive demo launches a server on port 8080 where users type an instruction and the model controls a Panda arm in MuJoCo. A fast path skips the optional depth-reasoning step, while setting THINK=1 enables the full reasoning path. The same policy transfers zero-shot to UR5e and xArm6 arms without retraining, because the policy speaks in hand poses rather than joint motors, and a standard controller handles inverse kinematics.
Real-time and evaluation demos
The package includes a real-time server that runs the MuJoCo simulation at wall-clock speed while the policy plans asynchronously in the background. During planning, the robot holds its current pose, then picks up the fresh plan when ready. This setup matches real-world robot deployment. For evaluation, a closed-loop harness runs full tasks in LIBERO across four suites: libero_10, libero_goal, libero_object, and libero_spatial, each with task IDs from 0 to 9. An open-loop replay on the DROID dataset steps through recorded episodes and overlays the model's predicted actions on ground-truth human teleoperator actions.
Reproducible configuration
All demos are tunable through environment variables. THINK toggles depth reasoning, NUM_STEPS sets the number of action steps, PORT changes the browser port, and SEED, SUITE, and TASK_ID make runs reproducible. EMBODIMENT selects between panda, ur5e, and xarm6. A preload command downloads all model and dataset assets into a persistent cache ahead of time. The Ryzen AI Max+ 395's integrated GPU and large unified memory pool let the model run on a desk-sized device, and the tutorial positions this as a practical starting point for local robotics prototyping with ROCm.
Sources & references
AMD: Running MolmoAct2 Robot Policy on an AMD Ryzen AI Max+ 395 Mini PC ↗Source consulted: 2026-10-15
 Apple
 NVIDIA